Manufacturer product photo · track configuration. The exact configuration is tailored to your project.
01 — ROBOT & MOTION
Cinebot Nano. Precision in space.
MRMC manufacturer specifications. Arm and track configuration values are listed separately.
Working range and speed
Max. reach from rotation centre
1 m
Height from base
1,3 m
Lowest position relative to base
−0,58 m
Max. camera speed / arm
3,2 m/s
Max. speed / arm + track
4,2 m/s
Max. track speed
1 m/s
Max. camera payload
7 kg
Dimensions and weights
Track length
1,45 m
Track width
23,5 cm
Width with supports
90 cm
Arm weight
25 kg
Track weight
22 kg
Weight of a pair of supports
2 kg
Total / arm + track + supports
49 kg
Range and speed of each axis
Base rotation
±360° / 200°/s
Shoulder lift
±360° / 200°/s
Elbow
±160° / 225°/s
Pan
±360° / 225°/s
Tilt
±360° / 225°/s
Roll
±360° / 225°/s
Control and motion repeatability
System software
Flair Lite
Manual position input
PushMoco
Trajectory repeatability
Motion control / multi-pass
Camera configuration
Depending on weight, balance and lens
Final shot speed
Depending on trajectory and setup
Source: MRMC — Cinebot Nano technical specifications · verified 29 October 2026. Maximum values describe system capabilities; each shot depends on the configuration and trajectory. Weights exclude the camera, lens, tripods and other equipment.
02 — OUR CAMERA SETUP
RED Helium S35. Tilta Nucleus-M V1.
Equipment available in Prague. We configure the camera setup for the shot, lenses and production requirements.
CAMERA / RED
RED Helium S35
Cinema camera with a HELIUM sensor. We confirm the exact body configuration, recording format and frame rate during project preparation.
LENS CONTROL / TILTA
Tilta Nucleus-M V1
First-generation wireless motorised follow focus. Nucleus-M supports focus, iris and zoom control. Motor count and configuration depend on the lenses and shot.
SUPPORT / ON LOCATION
Tripod-mounted setup
Tripod installation for studio and location work. We match camera height, support spacing and movement clearance to the shoot.
For preparation, we need the body, lens and accessories fitted to the arm. The 7 kg limit applies to the complete camera payload.
03 — OPERATION & POWER
Studio. On location. Off the grid.
Optional battery power extends location flexibility. We confirm capacity and runtime for the setup and shooting schedule.
System power supply
Input voltage specified by MRMC
110–264 V AC
Average power specified by MRMC
Less than 150 W
Battery operation
Available with our setup
Battery capacity and runtime
Confirmed for the specific project
Camera and accessory power
Depending on configuration
For shoot preparation
Base
Prague
Location
Studio / location / event
Mounting
Tripod-mounted setup
Space and working height
Depending on motion and configuration
Enquiry
Storyboard, date, location, camera and lenses
The electrical specifications above apply to the Cinebot Nano system, not all equipment on set. We confirm the battery configuration and runtime during technical preparation.
TECHNICAL PREPARATION
Let's discuss your shot.
Send your storyboard, lenses and an idea of the movement. Together, we'll choose the right configuration.
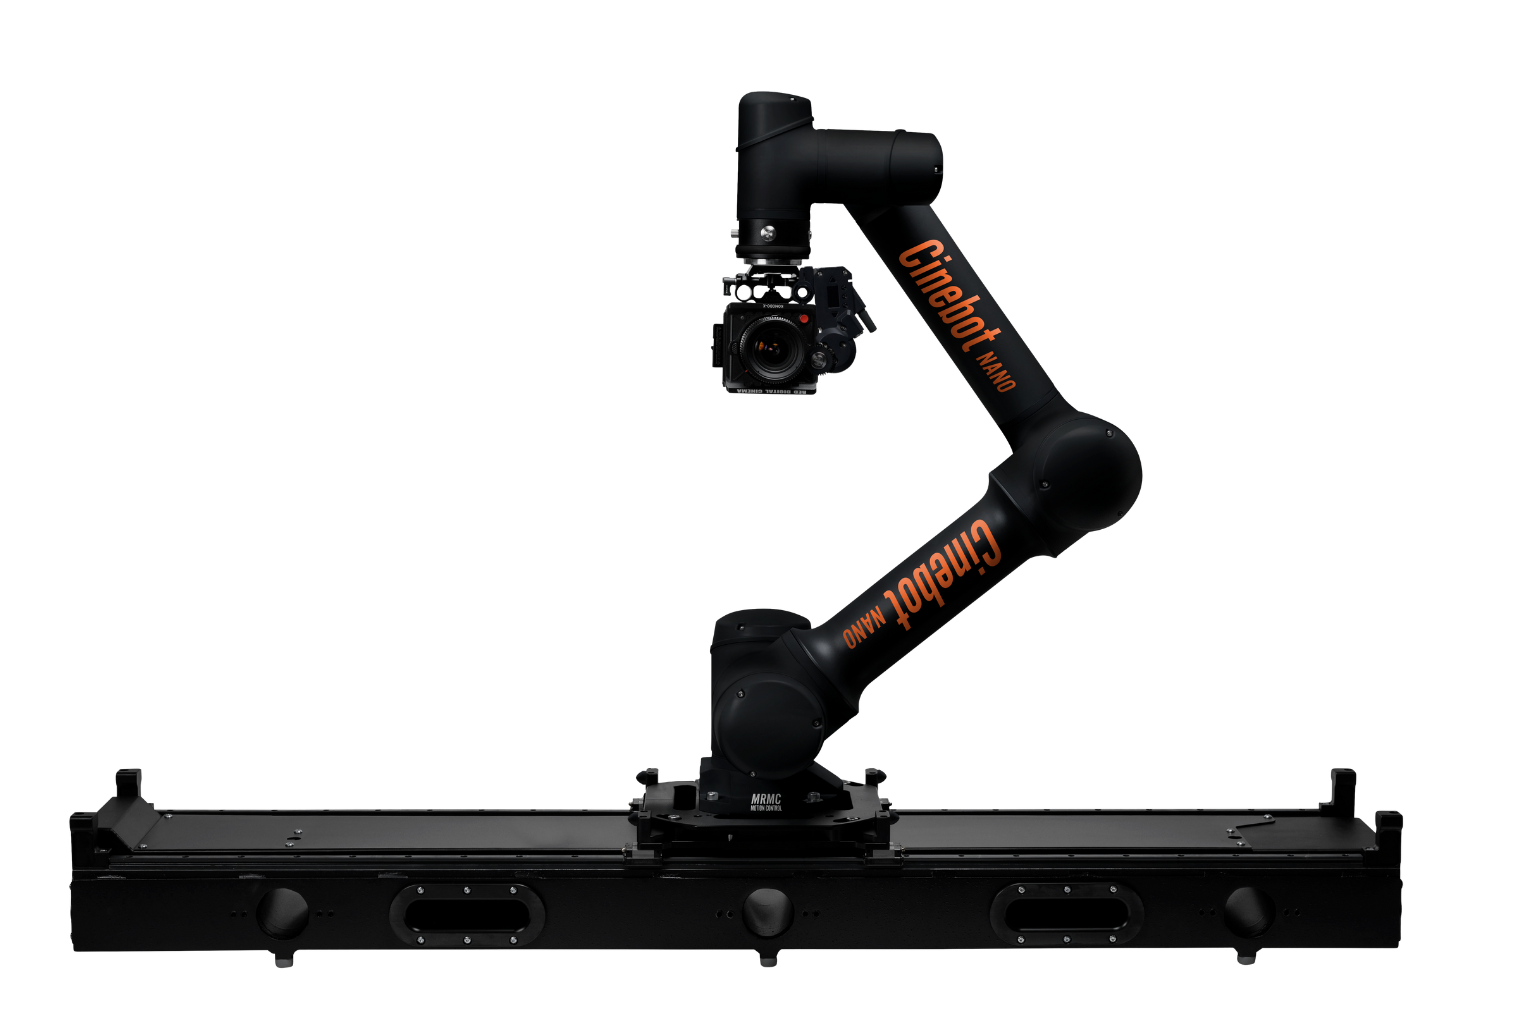 Manufacturer product photo · track configuration.